A conveyor can keep moving while a dark part, clear label or misaligned box passes the sensing point without a reliable signal. A photoelectric sensor detects object presence by sending light to a receiver, but the right arrangement—reflective, retroreflective or through-beam—depends on the target, space, alignment and environment.
This article is part of the computer hardware technology guide library.
Key takeaways
A photoelectric sensor is an optical presence detector: its output changes when the received light condition changes.
Reflective sensing reads light returned from the target; retroreflective sensing reads light returned from a separate reflector; through-beam sensing detects interruption between separate transmitter and receiver.
Through-beam is often the clearest choice when the target is opaque and a stable beam path can be installed. Reflective and retroreflective designs can be more compact, but target surface, transparency, contamination and alignment need checking.
The sensor head, reflector, power supply, controller input and conveyor are separate parts. Voltage, output type and wiring belong to the exact model documentation.
What a photoelectric sensor measures on a conveyor
A photoelectric sensor does not identify a product by itself. In a basic presence application, it observes the amount of light reaching its receiver and changes an electrical output when the configured detection condition is met. That signal can tell a PLC, counter or other controller that a part has arrived or crossed a point.
The physical sensor may contain an emitter and receiver in one housing, or the emitter and receiver may be separate. An external reflector is an optional optical component used by a retroreflective arrangement; it is not the sensor’s physical target. A controller, input module, indicator, bracket and conveyor are also external to the sensing element.
This is different from an optical distance instrument. ST explains that simple IR sensing can depend on returned signal strength, while time-of-flight products estimate distance from photon travel time. Do not describe every photoelectric switch as a precise distance sensor.
Reflective, retroreflective and through-beam: the practical difference
In a reflective or diffuse-reflective arrangement, the emitter and receiver are in one housing. The target itself returns some emitted light to the receiver, so the sensor and target face each other across the detection point. This can save space because no separate reflector is required, but colour, finish, angle, shape and surface cleanliness can change the returned light.
In a retroreflective arrangement, the sensor faces a reflector. The reflector returns the beam until an object crosses it, so the interruption becomes the detection event. This gives a defined beam path and can simplify alignment compared with two separately mounted heads, but transparent or highly reflective objects may need a model and setup intended for that behaviour. The reflector must remain mounted and clean.
In a through-beam arrangement, the transmitter and receiver are separate and the target interrupts the optical axis between them. It needs more installation space and two aligned units, but an opaque target does not have to provide a particular reflected brightness. Keyence describes this arrangement as offering a long detecting distance and stable detecting position.
These are sensing arrangements, not three universal performance grades. A model’s light source, sensing mode, output, range, response and environmental rating still control the real result.
| Arrangement | What triggers detection | Useful fit | Main check |
|---|---|---|---|
| Reflective | Light reflected from the target returns to the receiver | Tight space and simple one-head mounting | Target colour, finish, angle and cleanliness |
| Retroreflective | Target interrupts the beam between sensor and reflector | Defined beam path with one sensor head | Reflector alignment, transparency and contamination |
| Through-beam | Target interrupts the beam between separate transmitter and receiver | Opaque parts and a stable beam path | Two-unit alignment, wiring and available space |
How to choose a photoelectric sensor for parts or labels
Start with the object and the event, not the product label. Decide whether the target is opaque, transparent, shiny, dark, irregular or closely spaced. Then define the event: a leading edge crossing a point, a gap between parts, a label on a web, or simple presence inside a fixture.
Choose through-beam when an opaque target can pass between two aligned units and the rig can support them. Consider retroreflective when a reflector can sit opposite the sensor and a single-head installation is useful. Consider reflective when the target offers a repeatable return and the shortest mechanical arrangement matters. If a clear object or label is involved, read the model documentation carefully rather than assuming a generic photoelectric mode will work.
Check the physical installation before wiring: beam height, target path, bracket stiffness, vibration, nearby surfaces, wash-down or dust, and access for cleaning. A beam that is correct on a still bench can be unreliable if a bracket flexes or the target moves outside it.
The sensor output may be a switching signal for a PLC, counter or compatible controller input. Supply voltage, current, NPN/PNP or other output convention, normally open/closed behaviour, connector pinout and response time are model-specific. An “object detection circuit” is therefore not a universal wiring diagram; use the exact datasheet and an appropriate interface.
- Describe the target material, colour, finish, transparency and size.
- Mark the beam position and expected target motion on the actual rig.
- Select the optical arrangement that gives a repeatable light condition or interruption.
- Confirm range, response, output type, supply and environmental ratings in the model documentation.
- Test with the real target, real reflector if used, final bracket and likely contamination before relying on the signal.
Why a detection result can change
Optical detection depends on geometry as well as electronics. A reflective target can return different light when its angle or finish changes. Dust, oil, condensation or a dirty reflector can reduce the received signal. A transparent object may pass through a beam or create a weak change that a general-purpose setting does not interpret reliably.
Alignment is another common cause. In a through-beam setup, transmitter and receiver must remain aimed at one another. In a retroreflective setup, the sensor and reflector must stay aligned. Vibration, loose brackets and a changing conveyor path can turn a correct selection into intermittent detection.
Use the model’s adjustment or teaching procedure when provided, and validate the complete installed arrangement. Do not increase sensitivity blindly if the beam can see the conveyor frame, a nearby package or background surface. If the signal controls hazardous motion, a general-purpose photoelectric sensor must not be assumed to be a safety-rated protective device.
For Indian mechatronics learners, this topic connects directly to the Government of India DGT curriculum, which includes reflex photoelectric sensor behaviour, sensor logic and interfacing with actuators. The curriculum is a learning reference, not a substitute for the sensor manufacturer’s electrical and installation instructions.
Photoelectric sensor conveyor detection FAQs
These questions focus on the selection decision rather than a particular brand or model.
What does a photoelectric sensor detect?
It detects a change in received light associated with an object or interruption, then provides an electrical output. In a conveyor application that output can represent presence or passage; it does not automatically identify the product or measure exact distance.
Which is better: through-beam or retroreflective?
Neither is always better. Through-beam uses separate transmitter and receiver and can give a clear interruption signal for opaque parts, while retroreflective uses one sensor head and a reflector. Choose from target properties, space, alignment, contamination and the exact model specification.
Can a reflective photoelectric sensor detect a dark or shiny object?
It may, but the result depends on the sensor design, target surface, angle and setup. Dark, shiny or angled surfaces can change returned light. If the target is difficult, compare the model’s documented sensing method and validate it with the real object rather than relying on a generic claim.
Is a reflector part of the photoelectric sensor?
A reflector is an external component used by a retroreflective arrangement. The sensor head, reflector, bracket, wiring and controller input should be treated as separate parts when checking compatibility and installation.
Can I connect any photoelectric sensor directly to Arduino?
No. Check the exact sensor’s supply voltage, output type, current, logic compatibility, connector and interface requirements. An industrial sensor output may need an appropriate interface; do not copy a wiring diagram from a different model.
About the image
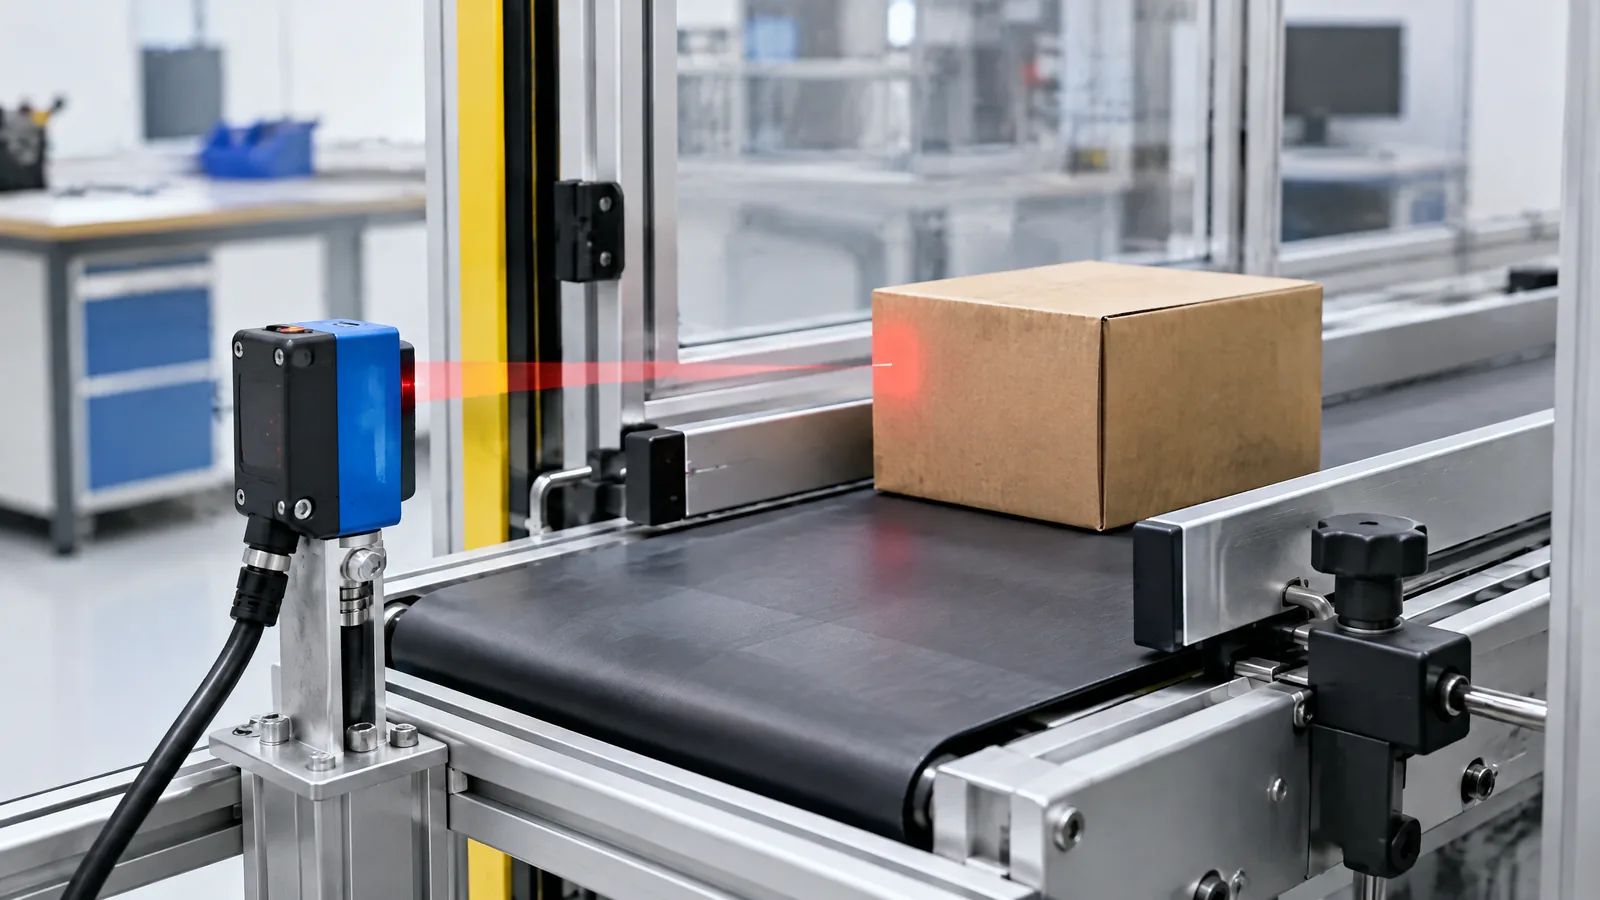
AI-generated editorial illustration; not an actual product or mission photograph.
Source notes
Reporting record
techduopulse stores source destinations privately. Public notes remain non-clickable so every visitor journey stays on this website.
Source note: KEYENCE photoelectric sensor principles and major types
Primary source · Reflective, retroreflective and through-beam operation; target and installation distinctionsSource note: OMRON industrial sensor selection and installation guidance
Primary source · Non-contact sensing definition; sensing distance, mounting, environment, vibration and mutual-interference considerationsSource note: STMicroelectronics optical proximity and ToF overview
Primary source · IR signal-strength limitation versus separate time-of-flight distance sensingSource note: DGT Technician Mechatronics curriculum sensor modules
Primary source · Reflex photoelectric sensor behaviour, sensor logic and actuator interfacing in the curriculumRelated reading: techduopulse proximity-sensor guide
Context source · Existing broad guide reviewed to avoid duplicating its general sensor overviewRelated reading: techduopulse IR-sensor guide
Context source · Existing general IR guide reviewed; application article remains distinctNew application article created from the supplied brief and four fetched authoritative sources. It compares reflective, retroreflective and through-beam photoelectric arrangements for conveyor presence detection, separates optional reflectors and external controller hardware from the physical sensor, and qualifies transparency, reflectivity, contamination, alignment, wiring and safety limitations without unsupported performance claims.